איך בוחרים ESC מתאים?
בחירת בקר מהירות לפי זרם מקסימלי, מתח, BEC, מרווח ביטחון, קירור והעומס האמיתי מהמנוע והמדחף.
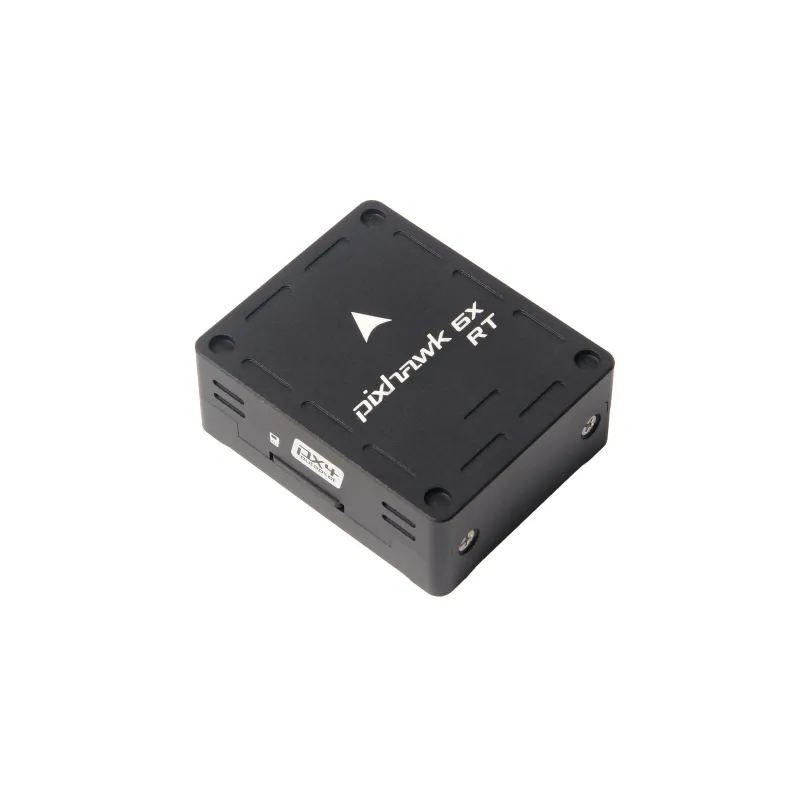


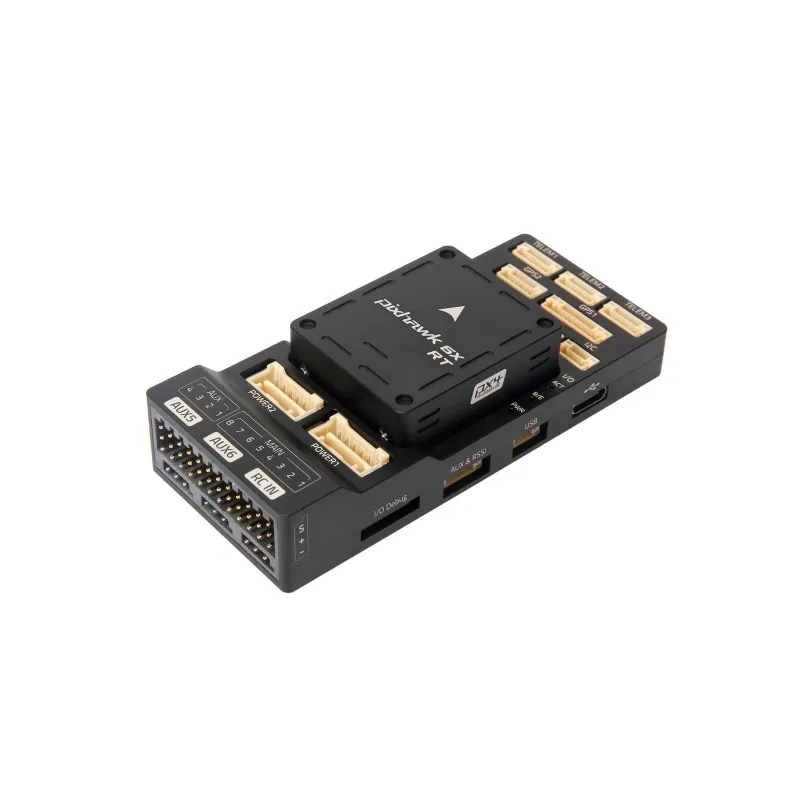

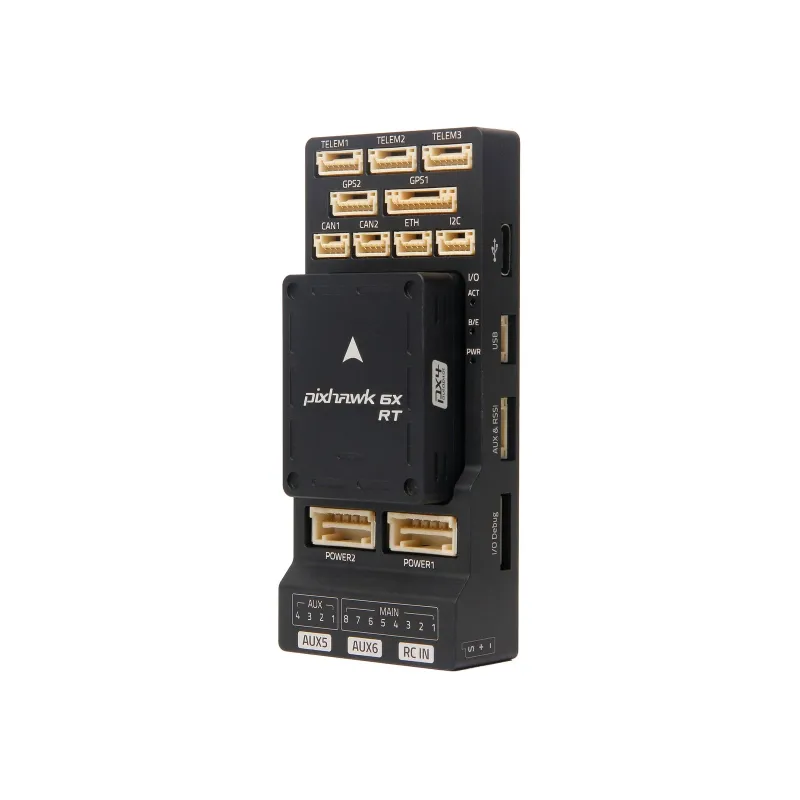
Holybro Pixhawk 6X-RT: פריט בקטלוג Holybro, בקטגוריית טייסים אוטומטיים ובקרי טיסה. הדף מיועד לבדיקת התאמה ולפנייה לגבי אספקה לשימוש אזרחי.
| מותג | Holybro |
|---|---|
| דגם | Pixhawk 6X-RT |
The Pixhawk 6X-RT is perfect for developers at corporate research labs, startups, academics (research, professors, students), and commercial application. This Flight controller is compatible with any baseboard that uses the Pixhawk bus standard, such as the Pixhawk Baseboard, Pixhawk Mini Baseboard, and Pixhawk RPi CM4 Baseboard.
Modular flight controller: separated IMU, FMU, and Base system connected by a 100-pin & a 50-pin Pixhawk® Bus connector.
Redundancy: 3x IMU sensors & 2x Barometer sensors on separate buses
Triple redundancy domains: Completely isolated sensor domains with separate buses and separate power control
Vibration isolation system to filter out high frequency vibration and reduce noise to ensure accurate readings
Ethernet interface for high-speed mission computer integration
IMUs are temperature-controlled by onboard heating resistors, allowing optimum working temperature of IMUs
This developer edition for early adopters while we continue to accumulate flight test hours
This Flight Controller is currently support in PX4 Flight Stack only. (Firmware Target: FMUv6xrt). It is not supported in Ardupilot at the moment.
This Flight controller uses digital or DroneCAN l power module (same as Pixhawk 6X, full list can be found here) Power module comparison chart
64MB Octal SPI Flash
IO Processor: STM32F103 32 Bit Arm® Cortex®-M3, 72MHz, 64KB SRAM
32 Bit Arm® Cortex®-M3, 72MHz, 64KB SRAM
On-board sensors Accel/Gyro: BMI088 Accel/Gyro: ICM-42688-P Accel/Gyro: ICM-42686-P Mag: BMM150 Barometer: BMP390 Barometer: BMP388
Accel/Gyro: BMI088
Accel/Gyro: ICM-42688-P
Accel/Gyro: ICM-42686-P
Barometer: BMP390
Barometer: BMP388
Hardware secure element
NXP EdgeLock SE051C2
RMII 100M Ethernet
Open-Source Software enablement
Pixhawk 6X-RT Flight Controller Module
Pixhawk Standard Baseboard v2A/Pixhawk Standard Baseboard v2B/Pixhawk Standard Baseboard v1
PM02D HV Power Module
Firmware Flashing Instruction (Github)
PX4 on the NXP IMXRT1176 1 GHz MCU - Presentation slides by NXP
i.MX RT1176 – product page 1 GHz Crossover MCU with Arm® Cortex® Cores
EdgeLock® SE051: Proven, Easy-to-Use IoT Security Solution with Support for Updatability and Custom Applets
| תצורה | מק״ט יצרן |
|---|---|
| Standard v2A | 11064+18117+15011 |
| Standard v2B | 11064+18125+15011 |
| FC Module Only | 11064 |
זמינות, מחיר, תכולת החבילה וגרסת החומרה יאושרו בפנייה. אין בדף התחייבות למלאי מקומי, זמן אספקה או מעמד של נציגות רשמית. יש לוודא התאמה למתח, למחברים, לקושחה ולדרישות ההפעלה לפני שימוש.
המדריכים האלו מסבירים את ההרכבה, בדיקות הבטיחות ובחירת האביזרים שבדרך כלל חשובים לסוג המוצר הזה.
בחירת בקר מהירות לפי זרם מקסימלי, מתח, BEC, מרווח ביטחון, קירור והעומס האמיתי מהמנוע והמדחף.
איך להתאים מנוע, ESC, סוללת LiPo ופרופלור כמערכת אחת ולא לבחור חלקים בנפרד.
מדריך בטיחות למדידת אמפר, וואטים ונפילת מתח כדי למנוע שריפת ESC, מנוע וסוללות LiPo.
מדריך להזנת מקלט וסרוואים: BEC פנימי ב-ESC, UBEC חיצוני, סוללת מקלט, יתירות ובטיחות בדגמים גדולים.
מספר תאים, קיבולת, C Rating, מחברים, משקל וזמן טיסה מוסברים בצורה פרקטית ללקוח RC.
תגיות: Holybro,
אנו משתמשים בקובצי עוגיות חיוניים להפעלת האתר. קובצי עוגיות שאינם חיוניים יופעלו רק לאחר הסכמה. ניתן לקרוא את המדיניות המלאה כאן.