איך בוחרים ESC מתאים?
בחירת בקר מהירות לפי זרם מקסימלי, מתח, BEC, מרווח ביטחון, קירור והעומס האמיתי מהמנוע והמדחף.

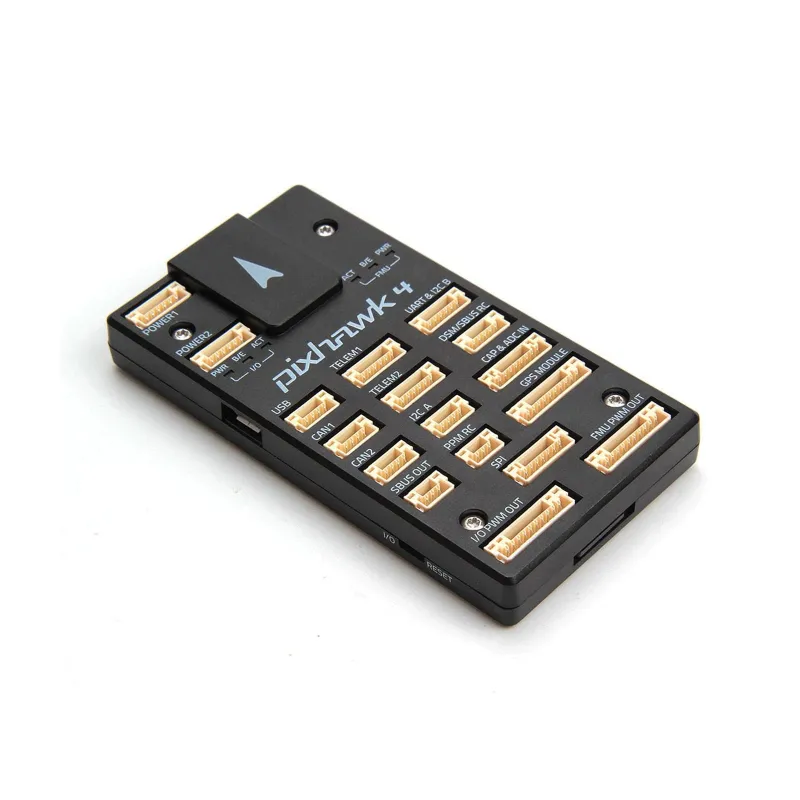
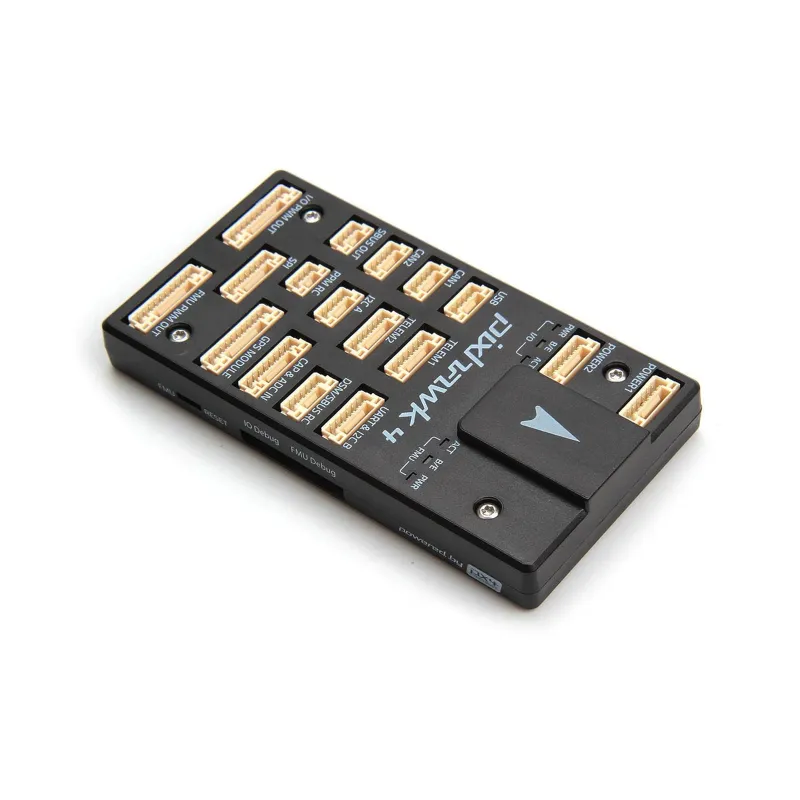
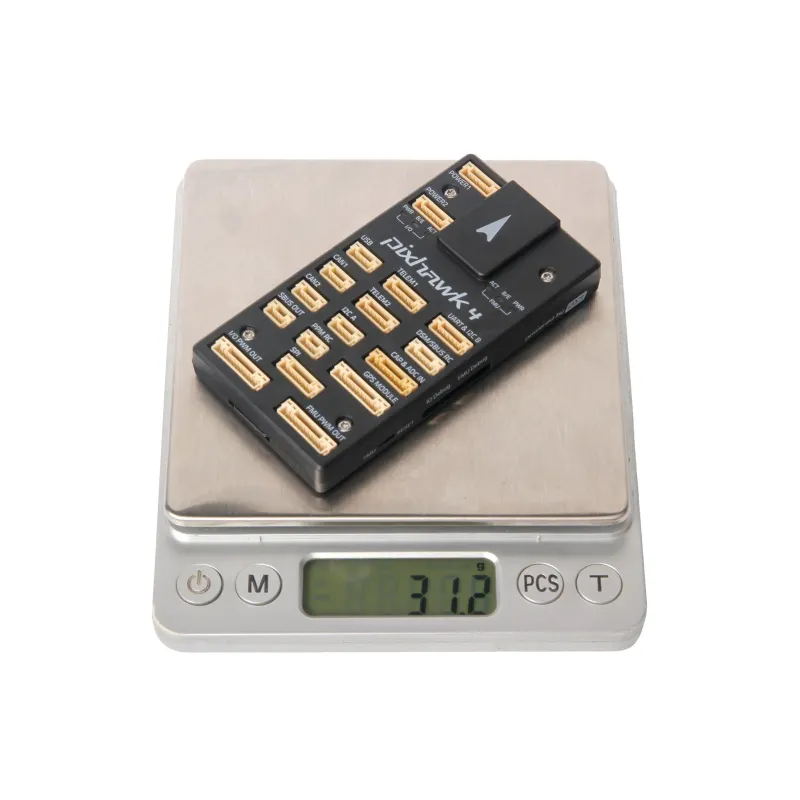
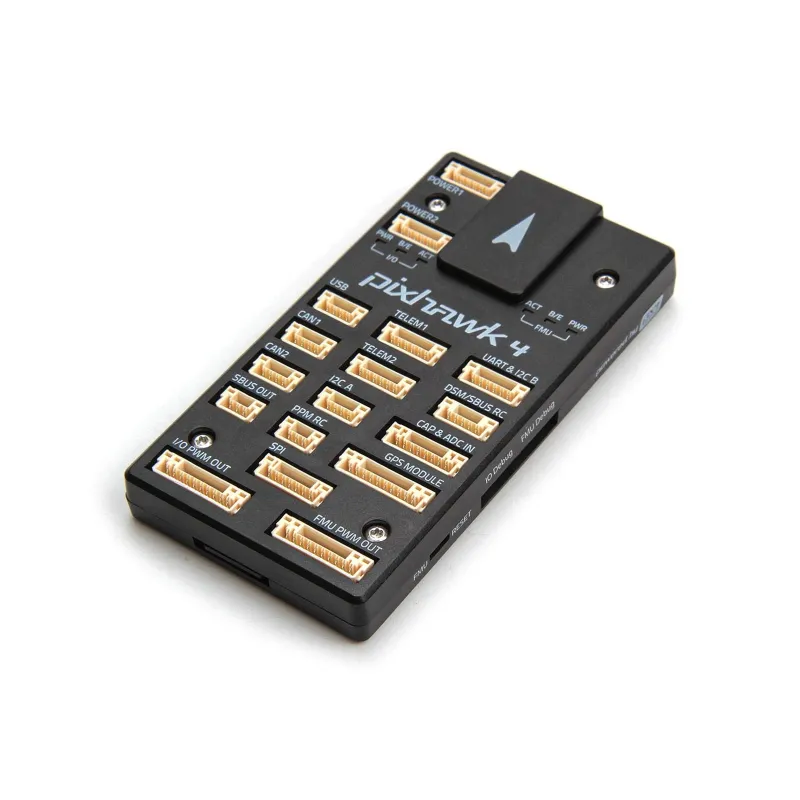
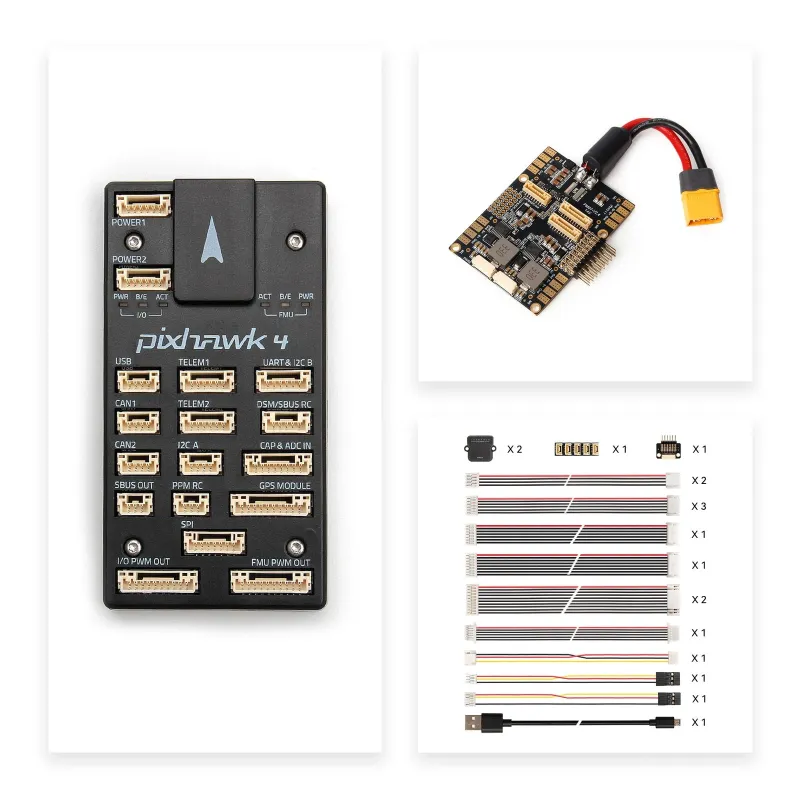
Holybro Pixhawk 4: פריט בקטלוג Holybro, בקטגוריית טייסים אוטומטיים ובקרי טיסה. הדף מיועד לבדיקת התאמה ולפנייה לגבי אספקה לשימוש אזרחי.
| מותג | Holybro |
|---|---|
| דגם | Pixhawk 4 |
Pixhawk® 4 features advanced processor technology from STMicroelectronics®, sensor technology from Bosch®, InvenSense®, and a NuttX real-time operating system, delivering incredible performance, flexibility, and reliability for controlling any autonomous vehicle.
The Pixhawk 4’s microcontroller has a 2MB flash memory and 512KB RAM. With the increased power and RAM resources, developers can be more productive and efficient with their development work. More complex algorithms and models can be implemented.
High-performance, low-noise IMUs on board are designed for stabilization applications. Data-ready signals from all sensors are routed to separate interrupt and timer capture pins on the controller, permitting precise time-stamping of sensor data. Newly designed vibration isolations enables more accurate readings, allowing vehicles to reach better overall flight performances.
The two external SPI buses and six associated chip select lines allow to add additional sensors and SPI-interfaced payload. There are total of four I2C buses, two dedicated for external use and two grouped with serial ports for GPS/Compass modules.
M10 GPS Requires PX4 1.14 & ArduPilot 4.3 or newer.
Power module comparison chart
Main FMU Processor STM32F765 - 32 Bit Arm ® Cortex® -M7, 216MHz, 2MB memory, 512KB RAM
STM32F765 - 32 Bit Arm ® Cortex® -M7, 216MHz, 2MB memory, 512KB RAM
IO Processor STM32F103 - 32 Bit Arm® Cortex®-M3, 72MHz, 64KB SRAM (Current) STM32F100 - 32 Bit Arm ® Cortex® -M3, 24MHz, 8KB SRAM (Discontinued)
STM32F103 - 32 Bit Arm® Cortex®-M3, 72MHz, 64KB SRAM (Current)
STM32F100 - 32 Bit Arm ® Cortex® -M3, 24MHz, 8KB SRAM (Discontinued)
On-board sensors Accel/Gyro: ICM-20689 Accel/Gyro: BMI055/ICM-20602 Mag: IST8310 Barometer: MS5611
Accel/Gyro: ICM-20689
Accel/Gyro: BMI055/ICM-20602
Barometer: MS5611
Power module output: 4.9~5.5V
Max input voltage: 6V
Max current sensing: 120A
USB Power Input: 4.75~5.25V
Servo Rail Input: 0~36V
Operating Temperature: -25-85°C
Dimensions: 44x84x12mm
Weight(plastic case): 33.3g
Weight(aluminum case): 49g
Pixhawk4 Quick Start Guide
Pixhawk4 DataSheet
Pixhawk4 Pinouts
SKU 11032/11035 Includes:
Pixhawk 4 Flight Controller (Plastic or Aluminum)
Controller + Power Module Set Includes:
Pixhawk 4 Flight Controller(Plastic or Aluminum)
Power Module: PM02 V3 12S/PM07 14S
| תצורה | מק״ט יצרן |
|---|---|
| Plastic / PM02 | 11032+15010 |
| Plastic / PM07 | 11032+15008 |
| Plastic / None | 11032 |
| Aluminum / PM02 | 11035+15010 |
| Aluminum / PM07 | 11035+15008 |
| Aluminum / None | 11035 |
זמינות, מחיר, תכולת החבילה וגרסת החומרה יאושרו בפנייה. אין בדף התחייבות למלאי מקומי, זמן אספקה או מעמד של נציגות רשמית. יש לוודא התאמה למתח, למחברים, לקושחה ולדרישות ההפעלה לפני שימוש.
המדריכים האלו מסבירים את ההרכבה, בדיקות הבטיחות ובחירת האביזרים שבדרך כלל חשובים לסוג המוצר הזה.
בחירת בקר מהירות לפי זרם מקסימלי, מתח, BEC, מרווח ביטחון, קירור והעומס האמיתי מהמנוע והמדחף.
איך להתאים מנוע, ESC, סוללת LiPo ופרופלור כמערכת אחת ולא לבחור חלקים בנפרד.
מדריך בטיחות למדידת אמפר, וואטים ונפילת מתח כדי למנוע שריפת ESC, מנוע וסוללות LiPo.
מדריך להזנת מקלט וסרוואים: BEC פנימי ב-ESC, UBEC חיצוני, סוללת מקלט, יתירות ובטיחות בדגמים גדולים.
מספר תאים, קיבולת, C Rating, מחברים, משקל וזמן טיסה מוסברים בצורה פרקטית ללקוח RC.
תגיות: Holybro,
אנו משתמשים בקובצי עוגיות חיוניים להפעלת האתר. קובצי עוגיות שאינם חיוניים יופעלו רק לאחר הסכמה. ניתן לקרוא את המדיניות המלאה כאן.